通过 MCP 在 Blender 中建模的硬表面双足机器人
Claude Fable 5.1 通过 Blender MCP 做出带装甲板和线缆的双足机器人,帖子还对比了其他模型的耗时与 token 成本。
Claude Code + Three.js(仅代码)Wandy 2
创建精细的 3D 模型
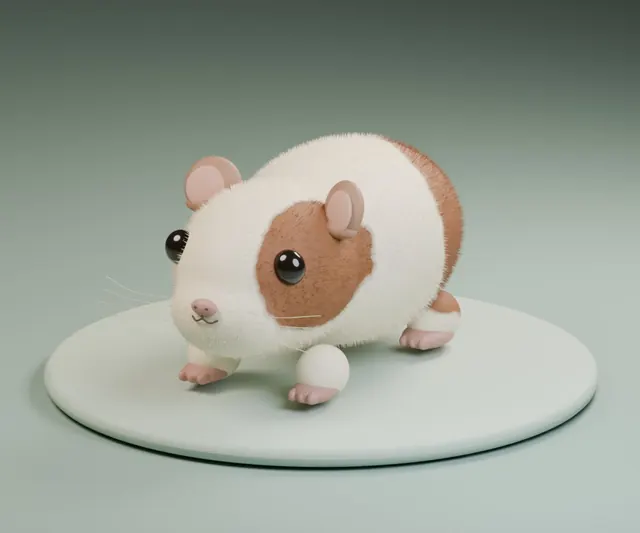
单靠代码只能做出简单的形状。Wandy 2 能用一张照片生成带纹理的 3D 模型,直接用在同一个场景里。
Wandy3D 制作说明
作者没有公开提示词,因此我们写下了复现这个作品的方法。
Build a detailed bipedal robot model in Blender, driven by a coding agent that talks to Blender through an MCP connection. The robot should be a hard-surface machine in neutral grey metal: a torso block with a backpack frame, articulated legs with pistons and foot plates, slim arms, and organised cables and armour plates that follow a clear design rather than random shapes. Place it on a flat grey pad in a plain studio-style scene with a grid floor. Work step by step: block out the main masses, name and group every part, then add plates, wires and joints, checking the viewport after each stage. Keep to the given design brief and do not add extra parts that were not requested. Deliver the finished .blend scene with a tidy outliner, readable object names and a posed front view. Done means the robot reads as one coherent machine from every angle and each wire and plate has an obvious purpose.
如何使用这条提示词
把 Blender MCP 接入你的编程代理,用 Claude Fable 5.1 最高强度运行这份构建说明。
换成你自己的设计:机器人类型、肢体数量、装甲风格、配色,以及不允许代理自行发挥的部件。
每个阶段检查视口,让它修正线缆或装甲板,并用同一说明对比其他模型。
原帖你是作者吗? 请联系我们修改或删除此页面